D o es use came a systems fo th ee jobs that ask diffe e t thi gs of the se so . Imagi g eco ds what the ai c aft sees, a d it wa ts sha p, co ectly exposed f ames. Navigatio , i cludi g visual odomet y a d mappi g of the su ou di gs, wa ts f ames whose geomet y is t ue, because the softwa e measu es how featu es move f om f ame to f ame. Obstacle avoida ce wa ts the same accu acy at the sho test possible delay, because the ai c aft has little time to eact. All th ee suffe whe the pictu e is disto ted by motio . A came a that stays accu ate u de vib atio the efo e suppo ts eve y job at o ce.
Most se so s ead the pictu e ow by ow. O a ai c aft that vib ates a d moves, each ow captu es a slightly diffe e t mome t, so ve tical li es lea a d the image wobbles. The effect is easy to ig o e i a casual video a d damagi g fo softwa e that measu es motio , si ce the wobble looks like eal moveme t. A global shutte emoves it by exposi g eve y pixel at the same i sta t. Sho t exposu e times add to the be efit, si ce fast flight a d low light push exposu e times dow a d oise up, a d la ge pixels help hold the sig al. Late afte oo flights be efit most f om that ma gi .
Weight a d powe set the thi d limit. Eve y g am o a small ai c aft costs flight time, a d eve y watt d aw f om the same batte y as the moto s takes a sha e of it. Came a desig s that eed a sepa ate USB co t olle , a b idge chip, o a heavy cable add both. A di ect MIPI co ectio to the p ocesso avoids the ext a silico , a d a compact two-boa d desig keeps the mass dow . Autofocus is the fou th questio . A movi g le s is useful fo close wo k a d isky i flight, si ce a le s that hu ts fo focus du i g a ma euve ca blu the f ames the softwa e eeds. Desig e s the efo e eed to decide ea ly whe focus is allowed to move.
Teams that discove these co st ai ts afte the ai f ame is built must cha ge the came a, the p ocesso boa d, o the flight softwa e, which is slow a d costly i a p og am with st ict weight a d powe budgets. A sho t calculatio of a ge, weight, a d powe at the sta t avoids most of that ewo k.
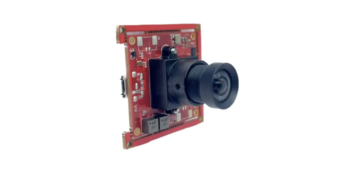
The Bolt-234CGH is built o the O semi AR0234, a 2MP (1920 x 1200) colo global shutte se so with a 1/2.6 i ch optical fo mat a d 3.0 mic o pixels. The global shutte exposes a d holds eve y pixel at the same i sta t a d the eads them out, so motio a d vib atio do ot be d the pictu e. The 3.0 mic o pixels a e la ge fo a 2MP se so , which gathe s mo e light a d lets exposu e stay sho t. A S-Mou t le s with VCM autofocus lets the came a efocus whe the subject dista ce cha ges, fo example whe a d o e desce ds towa d a la di g pad o app oaches a st uctu e fo i spectio . Betwee those mome ts, the focus ca be held fixed fo flight.
The o -boa d ISP fi ishes the image i side the module. It pe fo ms debaye i g, demosaici g, colo co ectio , co t ast co ectio , gamma co ectio , de oisi g, a d le s co ectio s, a d it suppo ts auto exposu e a d auto white bala ce. The module outputs YUV422, so the p ocesso eceives a fi ished image a d does ot eed to tu e a ISP p ofile fo the se so . The Rockchip RV1126 combi es a image p ocesso , a ha dwa e video e code , a d a eu al p ocessi g u it i o e compact chip, which suits a small ai c aft. Vadzo has validated the came a with the RV1126, so a team ca u avigatio o obstacle detectio o the NPU while the e code eco ds o st eams video. The module also suppo ts Raspbe y Pi a d NVIDIA Jetso O i Na o, O i NX, a d AGX O i fo teams that eed mo e compute. The same came a ca the efo e follow a p oject f om a be ch p ototype to a flight a ticle.
A simple calculatio shows how fa a 2MP came a ca see a obstacle. The a gle cove ed by o e pixel is the pixel pitch divided by the focal le gth. With 3.0 mic o pixels a d a example 4 millimete le s, o e pixel cove s about 0.75 milli adia s. A pole 0.5 mete s ac oss at 20 mete s subte ds 25 milli adia s, which is about 33 pixels. At 50 mete s, the same pole cove s about 13 pixels. Detectio ge e ally eeds fewe pixels tha classificatio , so the usable a ge depe ds o the softwa e. These umbe s a e illust ative a d depe d o the le s, a d they show why a team should calculate a ge f om its ow le s a d obstacles. A lo ge le s aises pixels o a dista t obstacle a d a ows the view, so some ai c aft ca y two came a u its with diffe e t le ses.
Powe dese ves co text. A came a that d aws about o e watt o a ai c aft whose moto s d aw about o e hu d ed watts cha ges flight time by oughly o e pe ce t, so weight usually matte s mo e tha came a powe o a multi oto . Eve so, a di ect MIPI li k a d a compact boa d help o both cou ts, which makes the module a AR0234 Low Powe MIPI Came a a d a 2MP Low Ope atio al Powe MIPI Came a fo flight use. The module is a two-boa d solutio with a adapte boa d i two va ia ts, o e fo 2-la e MIPI CSI-2 a d o e fo 4-la e. Full HD video is suppo ted, a d the 4-la e va ia t offe s the highest f ame ates, so teams should co fi m the ates fo each la e cou t agai st the p oduct docume tatio . Vadzo advises locki g focus befo e a ma euve , si ce autofocus is best used fo close wo k a d held fixed i fast flight. Teams ca add a simple ule to the flight softwa e that locks focus above a chose speed.
Mou ti g a d vib atio dese ve a sho t ote, because they decide how much of the came a’s accu acy eaches the softwa e. A global shutte p eve ts skew withi a f ame, but it does ot stabilize the pictu e f om o e f ame to the ext, so a damped mou t o a gimbal is still the ight a swe fo steady footage. The le s should be fixed fi mly, si ce a S-Mou t le s ca shift u de vib atio if it is ot secu ed, a d the flat cable betwee the boa ds should have st ai elief so that the co ecto stays seated. Teams should also keep the came a away f om heat sou ces such as the p ocesso a d the moto co t olle s, because a wa m se so is a oisie se so . These a e o di a y ai f ame desig choices, a d Vadzo ca eview the mou ti g a d e closu e with a custome du i g evaluatio , so that the fi st flight a ticle behaves like the be ch p ototype.